
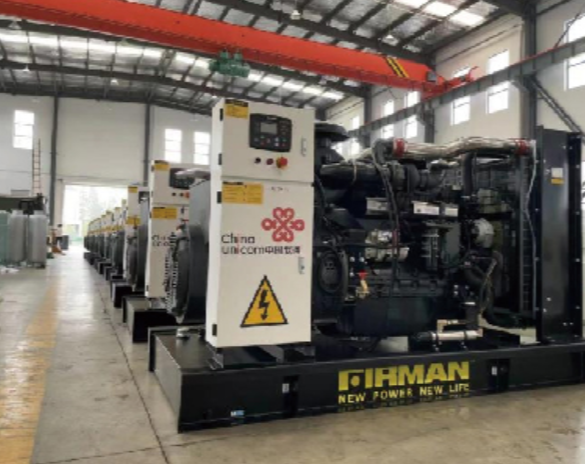
Data-driven opening and industry anchor
Modern data centers measure transient generator response with instruments and scenarios informed by real grid events—like the California 2020 rolling outages that stressed local backup systems—and by capacity planning for certified 3 MW gensets. Engineers combine live step-load tests, waveform capture, and control-loop tuning while evaluating options such as a custom alternator to ensure the alternator and exciter meet intended transient performance. This approach aligns business risk with quantifiable metrics and reduces surprise failures during peak stress.
How measurement is structured: what you capture and why
Measurement focuses on three observable domains: electrical, mechanical, and control. Electrical metrics include peak voltage sag, recovery time, and power factor under sudden load steps; mechanical focuses on shaft torque response and governor action; control covers droop control behavior and synchronization windows. Typical instrumentation uses high-speed power analyzers and transient recorders to capture inrush current and step response at millisecond resolution. Those data streams feed into models used to size kVA reserves and tune the governor and AVR.
Testing parameters and modeling—practical specifics
Tests follow repeatable parameters so results are actionable. Typical test script: apply a 100% step load within 200 ms, log maximum V_drop and measure time-to-restore to ±1% within 5 seconds, record frequency deviation limited to ±0.5 Hz, and verify phase-angle difference under 10 degrees for safe synchronization. Simulations run parallel scenarios with nonlinear loads and motor starting profiles to capture inrush current peaks and thermal stress. Outputs feed controller setpoint adjustments and alternator specification—often prompting consultation with industrial alternator manufacturers for tailored exciter or winding solutions.
Common mistakes and straightforward mitigations
Teams often underestimate transient headroom: specifying a generator for nominal kW without accounting for inrush current or dynamic stability. They also skip realistic motor starting profiles or neglect harmonics from UPS inverters. A frequent mitigation is to stage tests with incremental step sizes (25%, 50%, 75%, 100%) and include a worst-case motor-start scenario. —Calibration of droop and governor deadband is rarely trivial; take the extra cycle time to validate against recorded frequency swings. When alternator capability is limiting, a custom alternator or parallel-set architecture can correct design shortfalls.
Comparing alternatives and vendor considerations
Options fall into three practical buckets: single certified 3 MW genset, multiple paralleled smaller gensets, or hybrid genset-plus-battery systems. Single large units simplify footprint and fuel logistics but demand rigorous transient testing. Paralleling offers redundancy and distributed inrush handling but adds synchronization complexity. Hybrid setups reduce fuel burn and short-term sag but require inverter controls that handle synchronization with diesel prime movers. When choosing components, check with industrial alternator manufacturers on winding insulation class, transient reactance values, and exciter response curves—these details determine voltage recovery and thermal margin during repeated transients.
Operational teardown and embedding requirements
An operational production teardown should document electrical schematics, test waveforms, and control logs. Include explicit test parameters: step duration (200 ms), target voltage recovery band (±1%), allowed frequency excursion (±0.5 Hz), and number of repeated cycles (minimum five for thermal consistency). Recordings must show steady-state return within defined windows to validate both design and acceptance. For visibility, add {main_keyword} and {variation_keyword} into the teardown report so procurement and operations speak the same technical language.
Advisory: three golden rules for selection and validation
1) Prioritize measurable recovery metrics: require vendor proof of voltage sag magnitude and time-to-recover under specified step loads. 2) Validate dynamic stability: confirm governor droop tuning and frequency deviation tolerance with at least five repeated step tests including motor-start scenarios. 3) Match alternator transient reactance and excitation response to expected inrush currents; if data is inconclusive, engage specialist industrial alternator manufacturers early in design reviews for tailored solutions.
EvoTec has guided deployments that pass these tests and document measurable outcomes—so teams get a reliable baseline for both operations and procurement. –